Humanoid platform comparison
| Specification |
Unitree R1 EDU U2
Unitree
|
Unitree G1 EDU Plus U2
Unitree
|
AgiBot X2 Ultra
AgiBot (Zhiyuan Robotics)
|
Booster T2 Edu (base E1)
Booster Robotics
|
Booster T2 Pro
Booster Robotics
|
|---|---|---|---|---|---|
| Photo | 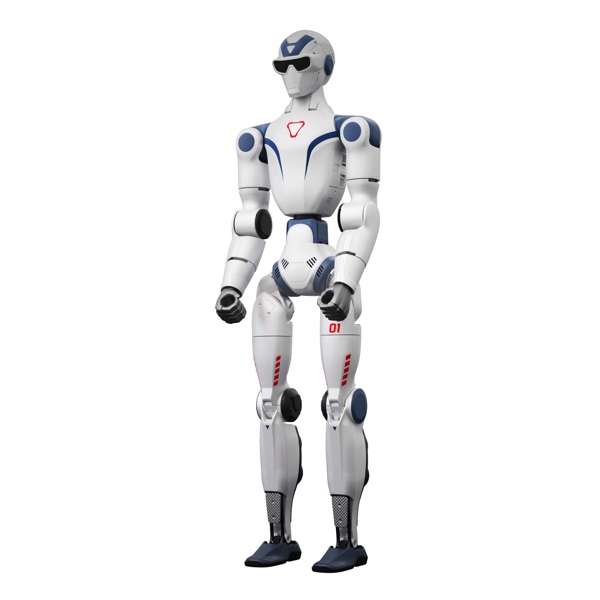 | 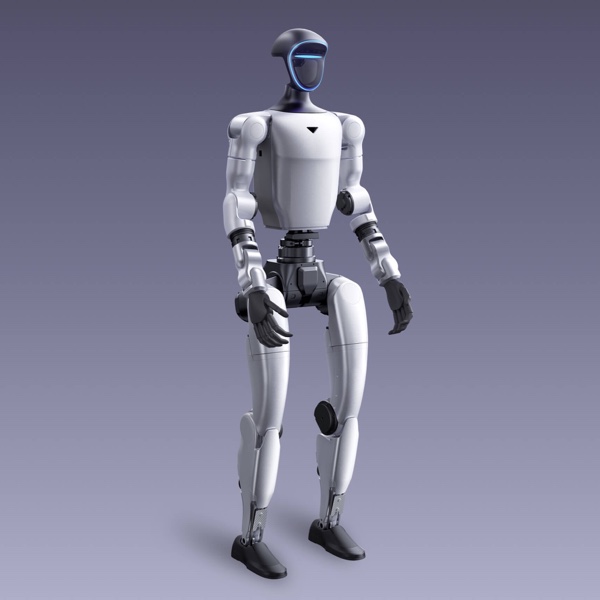 | 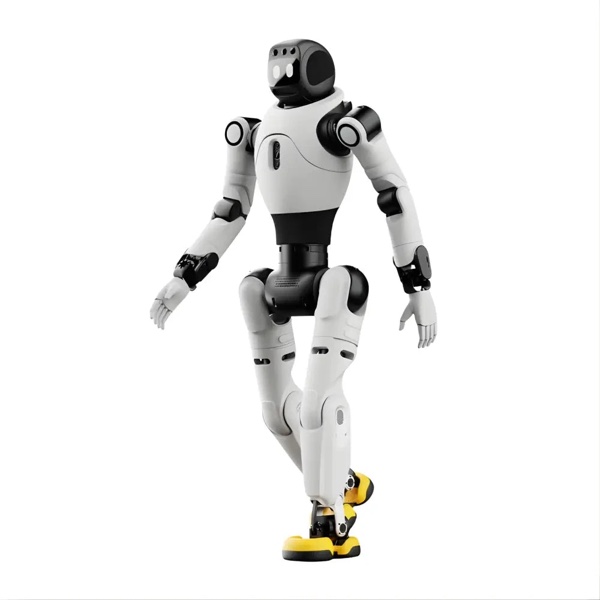 | 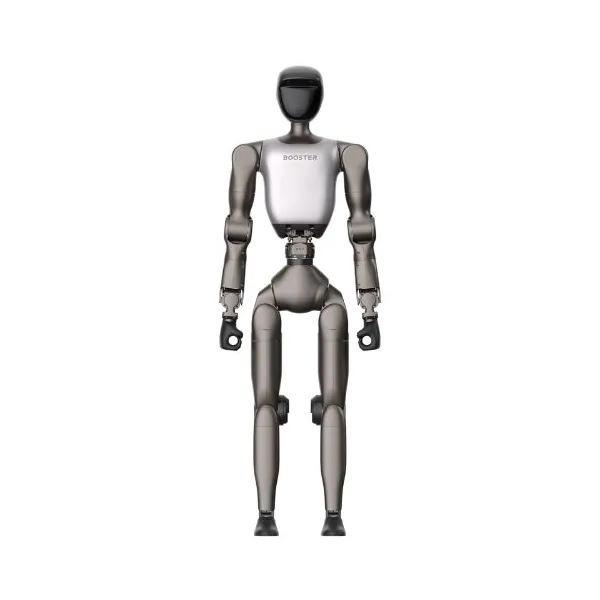 | |
| Height | 1.21 m | 1.32 m | 1.31 m | 1.40 m | 1.40 m |
| Weight | ~25 kg | ~35 kg | ~39 kg | ~42 kg | ~42 kg |
| Total DoF | 26 (12 legs · 10 arms · 2 waist · 2 head) | 29 (12 legs · 3 waist · 14 arms · 0 head) | 30 (12 legs · 3 waist · 14 arms · 1 head) | 31 (12 legs · 3 waist · 14 arms · 2 head) | 31 (12 legs · 3 waist · 14 arms · 2 head) |
| Cameras | Binocular depth camera module | 1 × Intel RealSense D435i (active depth) | 4 × RGB: binocular forward · interactive upward · RGB-D downward · rear | Ultra-wide 3D depth camera (head) + binocular waist · no rear view | Ultra-wide 3D depth camera (head) + binocular waist · no rear view |
| Camera FOV | 146° H × 124° V | 55.2° V, angled downward | Binocular 156° × 120° · interactive 110° × 80° · RGB-D 86° × 55° · rear 120° × 156° | 150° H × 94° V (depth camera) | 150° H × 94° V (depth camera) |
| LiDAR | ✕ | Livox MID-360, 360° H × 59° V | 3D LiDAR, 90° H × 120° V (forward-facing, not 360°) | ❌ · optional Super-hemispherical 3D LiDAR, €2,765 | ❌ · optional Super-hemispherical 3D LiDAR, €2,765 |
| Display | ✕ | ✕ | Face display, controllable via PlayEmoji (26 expressions) and PlayVideo | ✕ | ✕ |
| Audio | 4-mic spatial array + built-in speaker | 4-mic array + 5W speaker | Mic array + wireless mic + speaker · touch sensor on the head | Mic array + speaker · Hi Chat: real-time voice interaction · DUTCH LANGUAGE UNCONFIRMED | Mic array + speaker · Hi Chat: real-time voice interaction · DUTCH LANGUAGE UNCONFIRMED |
| Extra compute | NVIDIA Jetson Orin, 100 TOPS · UnifoLM multimodal model on board | Jetson Orin NX, ~100 TOPS | PC2 dev-unit: Jetson Orin NX 16 GB, 157 TOPS, 1024-core Ampere GPU, 512 GB · PC1/PC3: 2 × RK3588 | 16-core Arm Cortex-A78AE @ 1.9 GHz · 375 TOPS INT8 · 16 GB RAM · 512 GB | Jetson Thor T5000 · 14-core Arm Neoverse-V3AE @ 2.6 GHz · 2,070 TFLOPS (FP4, sparse) · 128 GB RAM · 512 GB |
| Toolchain | Unitree SDK2 · ROS 2 (rosbag2, MoveIt2) · NVIDIA Isaac Sim · CUDA/TensorRT | CUDA · TensorRT · JetPack · unitree_sdk2 · 785 third-party repos | AimDK_X2 · ROS 2 Humble · Python + C++ · custom aimdk_msgs · CUDA/TensorRT · only 20 third-party repos | ROS 2 native · open SDK Python + C++ · Booster Studio · simulation | CUDA · TensorRT · JetPack · ROS 2 native · open SDK Python + C++ · Booster Studio |
| Runtime per pack | ~1 h | 2 h | ~2 h | ~2 h · charges while in use | ~2 h · charges while in use |